Annotation- Problem Formulation: Processing radar information about aerodynamic targets, filtering of coordinate information remains an urgent problem. It is assumed that the target moves in a straight line and evenly most of the time, and less of the time, it makes various maneuvers. Target tracking is carried out at a rate equal to the survey time, in the presence of errors of coordinates measurements. Currently, there are number of filters for smoothing the target coordinate parameters. At the same time, the existing filters are characterized by a large error of smoothing in sections without a maneuver and small in sections with a maneuver, or vice versa - by a small error in sections without a maneuver and a large error in sections with a maneuver. Moreover, many filters work effectively only in some specified ranges of input parameters.
Aim: The new filter should provide a minimum smoothing error in areas without maneuver. It should ensure the minimum possible errors and emissions of smoothing error during the maneuver and operate efficiently over the widest range of input parameters.
I. INTRODUCTION
Currently, there is a large number of filters for tracking maneuvering aerodynamic targets used for processing radar information [1 - 8].
According to [1], such filters are divided into four types:
- without maneuver detection (WMD);
- with maneuver detection (MD);
- multialternative (IMM-filters);
- other, "exotic" (for example, particle filters).
At the same time, the task of providing effective smoothing remains relevant, and all types of filters have their drawbacks. As a rule, the first two types are characterized by small smoothing errors in those sections of the target trajectory where there is no maneuver, and large errors in the maneuver sections. As a rule, there are large errors during the maneuver. The third type, due to its internal settings, allows you to change the ratio of errors in the maneuver sections and its absence within a wide range. According to the literature, variants are often used, where relatively small errors are provided in the maneuver sections and large errors in its absence. In addition, many variants of filters of all types are a priori "tuned" to certain values of the intensity of the maneuver. This leads to the fact that smoothing errors significantly increase when the maneuver intensity parameters deviate from the settings.
The use of "exotic" filters has not yet shown an increase in filtration efficiency.
II. AIM OF WORK
When synthesizing the filter described in this article, the task was to create a filter that satisfies the following requirements:
- Filter should provide a minimum smoothing error in areas without a maneuver;
- Filter should provide the minimum possible errors and smoothing error during the maneuver;
- Filter should provide effective smoothing when the initial parameters change over a wide range (for example, maneuver intensity, measurement errors, review period - information updates), that is, the filter should not contain any settings.
III. PROPOSED WAY TO SOLVE THE PROBLEM
To solve the problem in this filter it is proposed to use random values of deviation of coordinate of newly measured target position (marker) from its extrapolated position. This deviation is proposed to be used to adjust the smoothing coefficients in order to consistently track the potential beginning of the maneuver. We assume that such tracking will increase the efficiency of filtering. In fact, in the particle filter such deviation is specifically generated. Here, in contrast to the particle filter, this random deviation is not generated artificially, but is taken already "ready".
Hereinafter the new filter will be called a filter with variation of coefficients (FVC).
As an initial analogue, we use an equal-precision, equal-discrete filter from [8], which is a variant of the Kalman filter for a linearly changing coordinate. Basic ratios for this filter:
where: is the extrapolated value of the coordinate on -th moment (period) of filtration;
are the smoothed values of the coordinate and the rate of its change on the -th moment;
are the smoothing coefficients at the -th moment for the coordinate and velocity, respectively;
is the difference between the measured value of the coordinate on the -th moment and the extrapolated value of ;
are the smoothed values of the coordinate and velocity on the -th moment of time; -the period of receipt of marks (review period).
In this analogue filter, the values of the smoothing coefficients and depend only on the step. When the values increase, and monotonically decrease, which means that we more and more "trust" our smoothed (extrapolated) values and less and less "trust" the newly incoming information (marks). It is known that such a filter for maneuvers of the target (deviation from rectilinear uniform motion) at sufficiently large values will give a large value of smoothing errors.
When synthesizing the FVC, lets fulfill the following conditions:
a) The smoothing coefficients should increase with increasing deviation and decrease with decreasing. The smaller the deviation, the less we "trust" him, and the more, the more we "trust" it. It allows you to quickly track the start of the maneuver by successive increase. Note that the smoothing coefficients become, as it were, "random".
b) The average value of the smoothing coefficients should not differ from the values calculated by formulas (2) and (3) in order to ensure effective smoothing in the absence of a maneuver. No worse than in analogue filter.
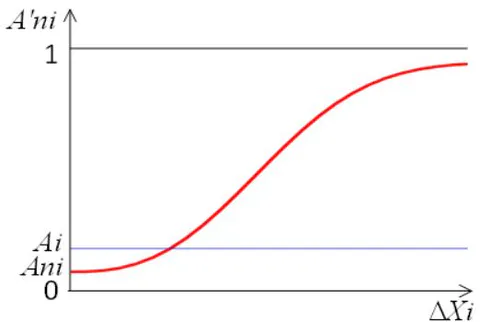
To fulfill conditions a.) and b.), we choose a function for adjusting the coefficients. The form of the proposed function for the coefficient is shown in fig.
On fig. 1 is the resulting value of the coefficient to be used in formula (5) instead of .
The value must be such that the average value for all is close to or equal to to fulfill the condition b.). When the value (possible maneuver) is increased, the value must increase.
IV. ALGORITHM OF FVC OPERATION
The finished FVC algorithm includes the actions listed below. Initial values for the filter are calculated according to Table 1 [9].
| i | Ai | Bi | XSi | VXSi |
| 1 | 1 | 1 | Xi | - |
| 2 | 1 | 1 | Xi | X2-X1/T |
We also input a new parameter "conditional step" (CS) for the -th step. The initial value of the CS is 3. We assume that we know the root-mean-square error (RMSE) of coordinate measuring.
The sequence of actions of the algorithm for .
Start. Getting a new value.
Extrapolation of coordinate by formula (1).
Calculation of tracking strobe size by coordinate:
where is the confidence coefficient (usually 3);
is a strobe coefficient, which takes into account the RMSE of extrapolation and measurement [10]:
- First adjustment of the CS. We "increase" the CS, so that later we get value less than value according to formula (2), in accordance with Fig. 1:
where is some increase coefficient of the step value. Note that the CS ceases to be an integer [10].
5. Calculation of the smoothing factor for CS according to formula (2):
Deviation calculation according to formula (4).
Relative Deviation Calculation
- Correction of the smoothing factor according to . The adjustment implements the function shown in fig. 1, but it is taken instead of .
is fiducial value of .
The proposed formulas for calculation shows:
Normality of random processes;
The need to provide the type of function for as in fig.
Calculation of the new value of CS. The expression for CS was obtained from (2) by solution a quadratic
equation, where is the argument and is the desired value:
10. Calculate the velocity smoothing coefficient using formula (3):
11. Calculation of the smoothed values by (5) and (6):
- Modification of the CS to the next step. The value is modified by one. Here we introduce the CS constraint [4]:
Experimental conditions are described in Table 3.
Further, when a new value is obtained, actions 1)... 12) are repeated.
Recommended parameter values for FVC are given in Table 2.
| Parameter | Meaning |
| K | 1,3 for ini<50 |
| 1,05 for ini≥50 | |
| Am | 0,2 |
| i nm | 20 |
V. SIMULATION RESULTS
The effectiveness of the FVC was evaluated using simulation modeling. For comparison, we used filters from those articles and books where the description can unambiguously determine the conditions of the experiment and interpret its results.
| Characteristic | Literary source | ||
| [6] | [2] | [3] | |
| Initial velocity | |||
| Initial position | - | - | |
| Period T, s | 1 | 1 | 2 |
| Maneuver period, maneuver acceleration | 50 – 70 s | 31 – 38 s | 22 – 46 s Centripetal (g - acceleration of gravity) |
| 38 – 49 s | |||
| 49 – 61 s | |||
| 61 – 65 s | |||
| 65 – 66 s | |||
| 66 – 81s | |||
| 81 – 90 s | |||
| End of experiment | 120 s and 240 s | 90 s | 80 s |
| RMSE | σX=5 m | Azimuth 0.02 rad, range 67.5 m | σX=250 m |
| Tested filters and their types | «VSD» - MD | «AWN» - MD | «Method1a» - WMD |
| «Al» - IMM | «CM» - IMM | «Method4a» - MD | |
| «VPN» - IMM | «VDF» - MD | «Method5a» - IMM | |
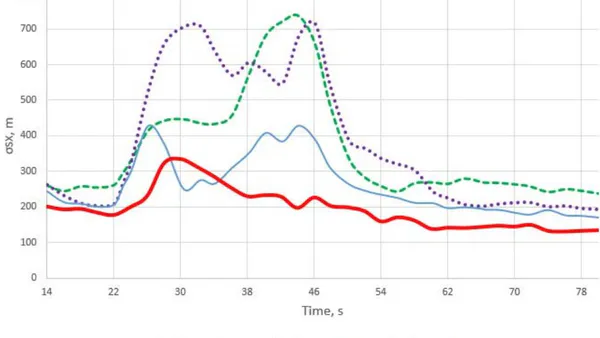
The simulation results for various filters from [6, 2, 3] and FVC are shown in Figs. 2 - 5 and in table 4. Figures 2 - 4 show the dependences of the smoothed RMSE along the coordinate on time (the graphs are plotted by characteristic points). Figure 2 shows dependences for [6], in fig. 3 - for [2], in fig. 4 - for [3]. Figure 5 shows the dependences of the RMSE of the smoothed velocity along the coordinate for the filters from [6] and FVC.
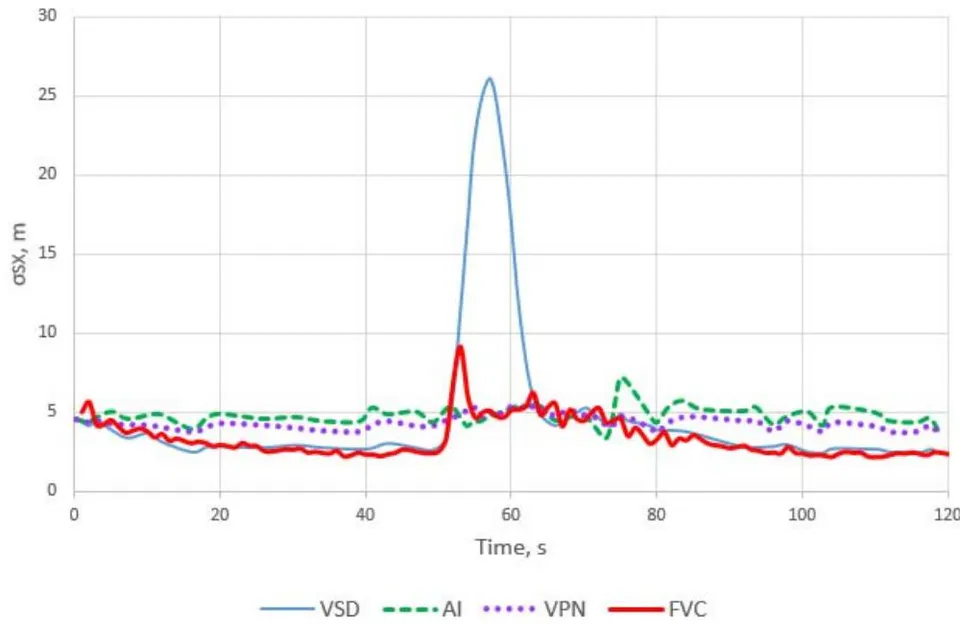
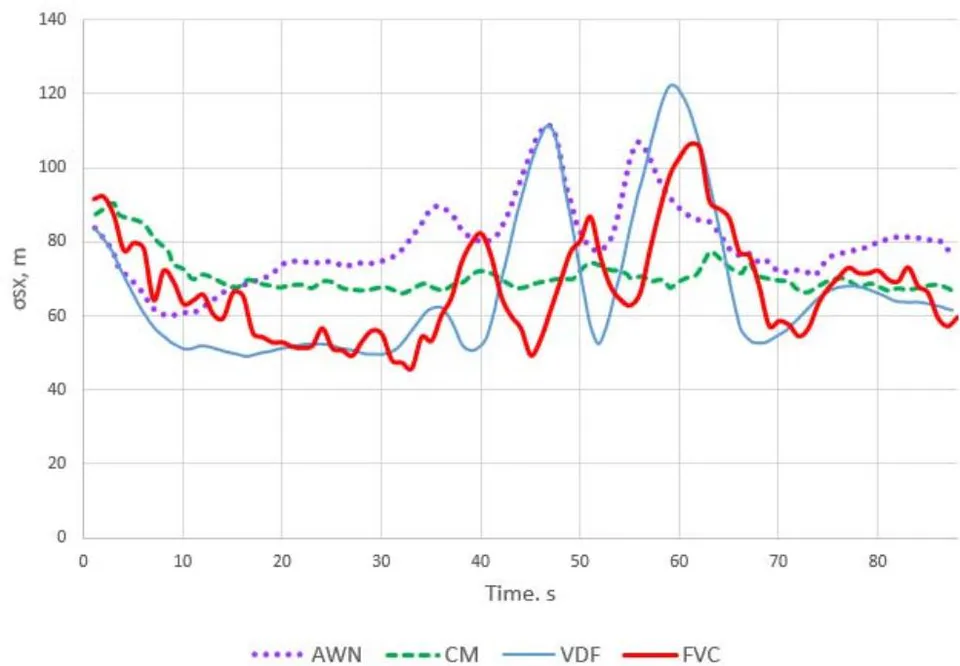
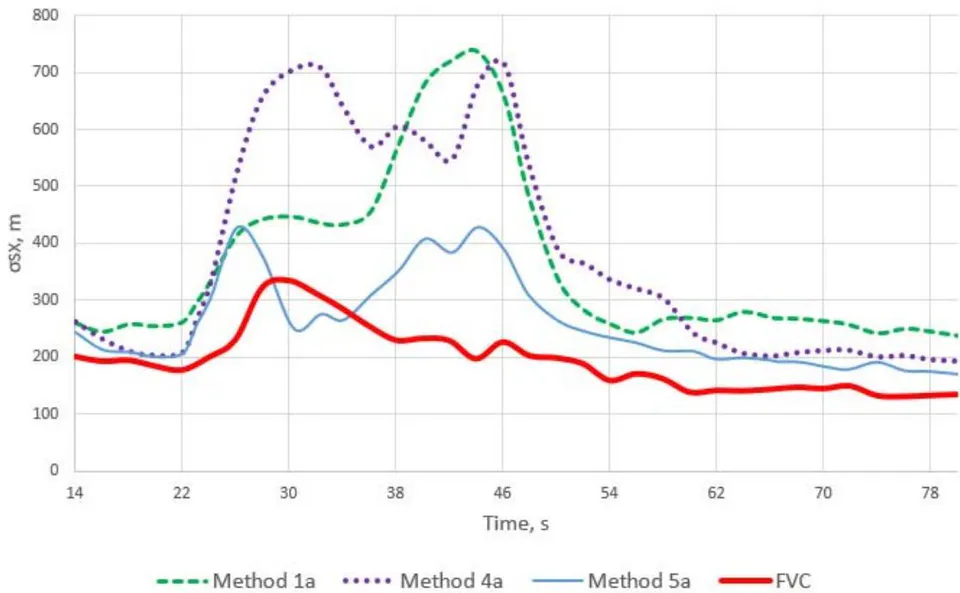
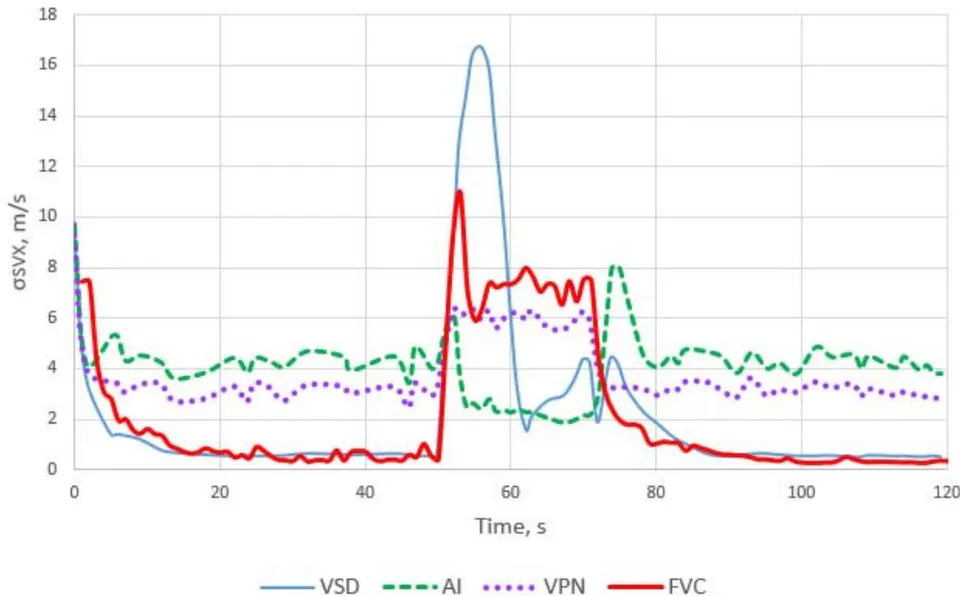
Table 4 shows the values of the total RMSE for all filters for two experiments.
| Filter | Experiment duration | |||
| 240 s | 120 s | |||
| \sigma SX, m | \sigma VSX, m/s | \sigma SX, m | \sigma VSX, m/s | |
| VPN | 4,12 | 3,51 | 4,35 | 4,30 |
| VSD | 4,92 | 2,92 | 7,88 | 5,17 |
| AI | 4,64 | 4,21 | 4,72 | 4,30 |
| FVC | 2,98 | 2,40 | 3,54 | 3,40 |
VI. THE DISCUSSION OF THE RESULTS
An analysis of the simulation results shows that the FVC provides a higher quality of smoothing (lower RMSE of the smoothed parameter) compared to other filters - see, for example, Table 4. Compared to the WMD and MD filters (VSD, AWN, Method 1a, Method 4a) FVC provides a smaller value of the error in the maneuver section. At the same time, the efficiency of smoothing in the absence of a maneuver does not decrease, as with filters of the IMM type (AI, VPN, CM, Method 5a - Fig. 2 - 5). The effectiveness of the FVC does not decrease with the input error value, scanning interval, intensity and duration of the maneuver.
VII. CONCLUSION
The proposed FVC does not contain maneuver detection means. It belongs to the WMD type.
An analysis of the simulation results shows that the FVC for tracking a maneuvering aerodynamic target provides a higher efficiency (lower value of the smoothed RMSE) compared to various other types and variants of filters and can be used in radar information processing systems.
It was achieved by introducing a new mechanism for adjusting the smoothing coefficients, taking into account the deviation of the mark coordinates from the extrapolated target position. At the same time, the proposed filter does not contain any settings for input errors, target maneuver parameters, review period, other factors.