
I. INTRODUCTION
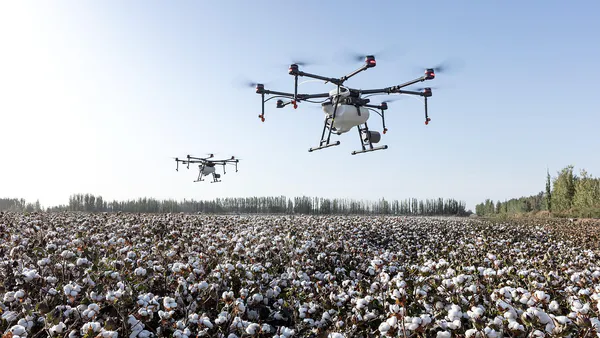
Drones have become increasingly popular for various civilian applications, including commercial, scientific, recreational, and agricultural tasks . However, their limited onboard battery capacity has been a challenge . The development in artificial intelligence and mechatronics technology have improved the capabilities of drones as aerial robots to making them cost-effective, user-friendly, safe, and environmentally friendly options . This paper reviews studies that propose solutions to optimize energy harvesting from UAV body vibrations and explore ways to increase flight duration by improving the design and capacity of existing batteries.
II. ANALYSIS OF POWER LOSS DURING FLIGHT
In the drone, power is lost during flight through mechanical loss ( ), magnetic loss ( ), iron ( ), and copper loss ( ). The total power loss ( ) is calculated by summation of this power.
The UAV energy consumption is calculated as
Where T is time is mints.
The total energy storage in the battery is calculated as
the total energy consumption percentage through the fighting is calculated as
The features and configurations of UAVs can vary significantly based on their missions. Developing accurate and efficient energy consumption models relies on thoroughly understanding of the contributing factors. Drone operations exhibit higher sensitivity to energy considerations than traditional vehicles . Various internal and external factors come into play, impacting energy usage. For instance, flying into headwinds has been observed to resulted in lower power consumption, attributed to increased thrust generated during the transition from hovering to forward flight . The weight and payload of UAVs emerge as crucial factors significantly affecting energy consumption . delve into an analysis of different parameters influencing the energy consumption of UAV routing problems, examining a scenario involving a single UAV on a multiple-delivery mission. The study highlights on the relationships between UAV energy consumption and influencing parameters. Drone design, environmental conditions, drone dynamics, and delivery operations are the four main elements influencing drone energy usage, as discussed by .
III. UAV POWER HARVESTING METHODS
The increasing demand of drones for various civilian and military applications challenges with their power consumption or battery capacity. This paper explores UAV power harvesting methods, focusing on advancements in artificial intelligence and mechatronics technology to enhance drone capabilities as aerial robots. The authors delve into solutions to optimize energy harvesting from UAV body vibrations and extend flight durations. The paper highlights the diverse strategies employed to make drones cost-effective, user-friendly, safe, and environmentally friendly.
Several studies have been conducted to address the limitations of drone battery capacity and enhance their overall functionality.
Mohamad Hazwan et al. introduces a real-time fault detection system for multirotor. Vibration sensors are attached to the multirotor arms to collect data, which is then analyzed by AI decision-making systems like fuzzy logic, neuro-fuzzy, and NN. The fuzzy logic method performed the best in indoor testing, while the neuro-fuzzy or NN methods may be more effective outdoors. The study suggests expanding the research to include other parameters like propeller vibration, motor condition, and battery level. Also use the accelerometer to measure vibration. using of a printed circuit board (PCB) can reduce wiring and unwanted interference [31].
Matej Karasek, Discusses the significance of stability in flying systems and introduces a new model that incorporating vibrational stabilization. This form of stability is essential important for larger flyers like hawkmoths and hummingbirds. The paper also explores the potential applications of vibrational stabilization in flapping-wing robots and MEMS sensors [32].
Kejing Chen et al, introduce the vibration modes of large-scale multi-rotor manned drones by analyzing small-scale drones through experiments and finite element analysis. It found that, accelerometers measure drone vibrations to some extent. The study also developed a second-generation large-scale drone based on the vibration characteristics of small-scale drones. Circular tubular arms were found to have strong vibrations in the z-axis direction, while elliptical arms effectively reduced vibrations in the same direction. Factors such as motor mounting position and connection between the arms and the body were identified as influences on vibrations, with longer arms causing more noticeable vibration. The study suggested that connecting structures between adjacent arms can help decrease vibration in the drone's beam structure [33].
Xunhua Dai et al, describe the optimization of the UAVs systems, by modeling various components such as the propeller, ESC, motor, and battery. Mathematical derivations estimate important parameters for each element, resulting in improved efficiency. The effectiveness of this approach is demonstrated through experiments and feedback. Optimizing the propulsion system is crucial for designing multicopters and other aircraft systems, and the theoretical analysis can also be extended to enhance the endurance of UAVs, providing opportunities for future research [34].
Abera Tullu et al, discuss the increase use of small-scale UAVs for law enforcement missions, and the need for robust autonomy in these drones. However, using multiple sensors for environmental information is often impractical due to weight and cost constraints [35].
Adam Dáugosz et al. utilized the optimal design of a drone wing made of composite materials. The goal is to improve strength and rigidity while reducing weight. The study uses a multi-objective evolutionary algorithm to optimize the wing structure. Numerical simulations and experimental tests are used to validate the design. The results show that the current design is more rigid than all the other solutions found, and the ideal Pareto solution set offers a range of diverse options for the designer to choose from. Overall, the optimization task of the drone wing design is challenging, but this study provides a promising approach to improving current designs [36].
Heung Soo Kim et al. discuss the use of piezoelectric energy harvesting from vibration sources and the limitations of using monolithic or biomorphic ceramic layers. It introduces piezoelectric total fiber composites (MFC) and three new substrate materials (copper, zinc alloy, and galvanized steel) for energy harvesting. The study includes Computational Fluid Dynamics (CFD) and finite element analysis (FEA) to analyze the performance of different substrate materials and the effect of MFC patches on the shape of an airplane wing. The results show that using MFC patches can improve the aerodynamic performance and stability of the aircraft [37].
Nikola Gavrilovic et al. introduce the feasibility of using wind energy for small UAVs, and the potential for maximizing energy extraction from wind fluctuations. The equations of motion and energy equations are used to develop control strategies that minimize energy usage during flights and maximize energy obtained from wind fluctuations. The study also explores the effects of complex and random three-dimensional wind fields on aircraft performance and power acquisition. The future focus will be on defining the design process and optimal strategies for extracting energy from storms, flight tests with wind measurement systems are necessary for complete understanding of the dynamics and energy exchanges involved [38].
Rocco Citroni et al. develop new strategies for expanding the parameters of small air vehicles (MAVs), specifically in terms of travel distance and mission duration. The first section of the paper presents a model to analyze the energy consumption of drones and proposes different scenarios for improving mission parameters. The second section discusses the design and simulation of a harvesting machine using plasmatic Nano atom technology, which shows potential for enhancing parameters. The results suggest that a hybrid system with the harvesting machine and a new rechargeable battery could indefinitely power the MAVs. [39].
Rutuja Shivgan et al. a model for drone path planning that considers energy consumption. The model focuses on drone acceleration, deceleration, hovering, and turning. The problem of finding an energy-efficient path is formulated as a traveling Salesman problem. The paper proposes a genetic algorithm to minimize energy usage by reducing the number of turns. The results demonstrate that the genetic algorithm with energy optimization significantly reduces energy consumption compared to the greedy algorithm, with more significant savings as the number of waypoints increases [40].
ALPER ERTURK et al. The study initiated a new L-shaped energy harvester design that can produce a broader range of energy. The authors propose an electromechanical model to analyze the harvester's behavior and suggest methods to avoid voltage cancellation. Additionally, the text discusses the potential use of the L-shaped harvester as a landing gear for drones, comparing it with a curved power harvester beam. The theoretical benefits of the L-shaped design are emphasized, and experiments are being conducted to confirm its performance [41].
Georgia Foutsitzi et al. The study aimed to optimize the design of a cantilever piezoelectric energy harvester (PEH) by considering multiple criteria, such as maximizing power output, minimizing system mass, and ensuring maximum bending stress constraint. Three optimization algorithms were used, and the results showed that all algorithms converged to the base Pareto optimal front after approximately ten generations. However, only the GDE3 algorithm could generate solutions with power output exceeding 284 mW/g2. Additionally, GDE3 outperformed the other algorithms regarding solution quality metrics [42].
Pedram Beigi et al. This paper explores the increasing demand for drones and how their energy consumption is crucial in determining their effectiveness. It provides an overview of research on the energy consumption of UAVs and examines the factors influencing their energy consumption during missions [43].
Alastair P et al. present static modeling approach for VTOL UAV power systems, the model accurately predicts losses and efficiency but tends to overestimate energy loss. The paper also showcases the application of the model in different power system architectures, highlighting the advantages of a hybrid system with a hydrogen fuel cell, which enables a lighter vehicle with increased payload or flight time. However, using a boost converter to a DC fixed bus reduces efficiency and flight time compared to the traditional approach [44].
Mohamed Nadir P et al. This paper examines the energy aspect of UAV propulsion systems and compares different power supply architectures and energy management strategies. It emphasizes the importance of hybrid power sources for better performance in various operating conditions. The paper also addresses the challenge of achieving unlimited endurance, and the lack of specific energy management approaches compared to electric cars. Due to limitations in weight and computational ability, real-time power optimization is limited, resulting in offline optimization based on prior knowledge of the task. The paper also discusses various power supply technologies, including switching [45].
Bowen Zhang et al. describe the different technologies used for propulsion in UAVs, such as fuel power, fuel-electric hybrid power, and electric power. This paper examines various power sources and their advantages, considering environmental concerns and the potential of electric propulsion systems. It emphasizes the importance of selecting suitable energy storage devices, distributed propulsion systems, high-energy-density motors, and superconducting motors. However, the paper also acknowledges the limitations in batteries, engines, and power management, especially for larger drones. The future focus should be developing safe and high-density energy storage technology, efficient motors and transformers, and adequate heat management technologies [46].
Jing Zhang et al. the author introduces the potential benefits of using solar-powered UAVs to increase flight time and decrease the need for human intervention in charging the drone batteries. Through augmented learning, the paper demonstrates that optimal decisions can be calculated, leading to increased communication productivity and harvested energy for UAVs, as shown in simulation results [47].
Yixin Yan et al. This paper proposes a magnetic resonance wireless charging system for lithium-battery powered drones, to address the limited battery life issue. The system comprises a transmitter inverter circuit, a coupling device, and a receiver rectifier circuit. The authors derive expressions for power reception and transmission efficiency to guide the system's design. ANSYS Maxwell analysis shows that the magnetic field is concentrated within a radius of 30 mm around the transmission coil. Experimental results demonstrate that the system can maintain stable self-induction of the coupling coil even when displaced, overcoming the low charging efficiency caused by coil misalignment during UAV landing. The system provides a constant voltage output, and the established model is accurate [48].
Zhaohui Yang et al. The paper investigates wireless communication system for energy harvesting capabilities. The system allows drones to deliver energy to users and users to harvest energy for data transfer. The problem is divided into two sub-problems: path planning and energy minimization with fixed path planning. The optimal solution is obtained through various optimization techniques. The paper also suggests that drones should stay directly overhead low- height users for efficient power and information transmission. [49].
Toan V. Quyen et al. The proposed study aims to overcome energy constraints and optimize the harvested energy for UAVs. The study focuses on using radio frequency (RF) and solar energy as sources for energy harvesting. By combining these two energy sources, the output power for the drones is increased to meet the required power parameters. With a charging system, a constant voltage of up to 23.2 V can be achieved, satisfying the standard drone battery requirements. The proposed hybrid system has been optimized, evaluated, and compared to other systems. To further improve the system performance, the charging treatment of the battery and the MPPT algorithm for the solar system should be considered. [50].
Jingjing Yao et al. propose power control in time varying IOD networks with wireless charging for data collection. The authors propose an MDP model and a deep critical actor reinforcement learning algorithm to optimize radio transmission power for each drone, aiming to reduce power consumption. Simulations demonstrate the superiority of their algorithms over existing ones, with their performance being impacted by learning rates and the number of neurons in the actor-critical components [51].
Koszewnik et al. The text enclosed using one-dimensional structures with piezo patches for energy harvesting. It focuses on optimizing the location and parameters of a piezoelectric Harvester connected to one arm of a six-rotor drone for maximum energy harvesting. Adding piezo harvesters to each arm of the drone can extend its flight duration, and further research will be done to improve the energy harvest of each arm [52].
Matthias Perez et al. the researchers conducted an analyzed of the vibrations and electrical energy generated by a quadcopter drone. They aimed to harvest energy by integrating piezoelectric elements into the drone's structure. They tested commercial and homemade transducers and found that while the energy levels obtained from the commercial transducers were suitable for sensor applications, they were insufficient to prolong the flight time. The homemade transducers showed potential, but further improvements are needed regarding adhesion and shelf life [53].
Wang, J et al. a new high-performance piezoelectric energy harvester called the three-stability runner (TGPEH). The researchers analyzed the output characteristics of TGPEH under different wind speeds and load resistance and found that it outperforms conventional power harvesters by having a lower threshold wind speed and higher output voltage. The paper also explores the transformation of potential energy into kinetic energy in the TGPEH. It discusses the increase in output voltage during the transition from oscillations inside the well to oscillations between wells. Additionally, the TGPEH exhibits a higher output power than conventional power harvesters. However, the output response of TGPEH is greatly affected by the initial conditions during the movement between potential wells [54].
Ashleigh Townsend et al. This paper introduces combustion engines, solar energy, hydrogen fuel cells, and supercapacitors. hybrid systems combining different power sources can address issues such as slow charging and poor peak power supply. Supercapacitors are commonly used in hybrid systems due to their benefits. However, more research is needed to explore the effectiveness of supercapacitors in fuel cell systems for drone applications [55].
Cuong Van Nguyen et al. propose a hybrid RF solar harvesting system to improve the flight times of drones. The system addresses the performance drop issue in autonomous systems and introduces new designs and results to solve this problem. The study also suggests enhancing efficiency and reducing bypass time by using fuzzy algorithms or PSO to control the duty cycle of the DC-DC boost transformer. This hybrid can power the drones directly and charge their batteries simultaneously. Additionally, the paper mentions the possibility of increasing the battery storage capacity as another improvement [56].
Silvia Sekander et al. The text found the development and verification of statistical models for renewable energy harvesting. It explains the significance of accurately predicting and monitoring renewable energy sources. It discusses various statistical techniques like Time Series Analysis, Regression Analysis, and machine learning algorithms used to create these models. It also highlights the challenges in validating and verifying these models, including data quality, model robustness, and the impact of external variables [57].
NABIL A. AHMED et al. a new electric power train for solar-powered UAVs. The proposed system utilizes a Zyphry UAV for AC line feed to power the fans and includes solar panels, a lithium-sulfide battery-based power management system, an inverter, and an active output filter (AOF). The AOF reduces the size and weight of the power transmission system, improves conversion efficiency, and reduces unwanted harmonics. Simulation and experimental results demonstrate the effectiveness of the proposed system, which achieves high-quality sinusoidal line voltage waveforms with low distortion. We suggest further investigation of the proposed AOF for application in large-scale photovoltaic power plants [58].
Khac Lam Pham et al. The experiment focused on converting wind energy to electric energy and found that it is a promising method for powering UAVs. Overall, the paper highlights the importance of power supply in the operation of drones and suggests potential methods for improving their efficiency [59].
Karan. Jain et al. applied the concept of staging power sources for UAVs, focusing on multiple engines. The aim is to remove energy sources that no longer save energy, reducing the vehicle's weight and thus reducing energy consumption. The article presents a model for predicting the flight time of a multistage helicopter based on power supply and consumption parameters. [60].
Mohamed Nadir Boukoberine et al. bounded the limitations of battery-powered drones regarding endurance and proposes various solutions to address this problem. These solutions include switching the laser beam in-flight for recharging, a hybrid power supply system that combines battery with fuel and solar energy cells, and supercapacitors. The paper also provides a comparative and critical study of different power supply architectures, aiming to facilitate selecting a suitable power supply system for UAVs. Additionally, the paper highlights the importance of power supply systems in drones and provides recommendations for future research [61].
Krzysztof MATEJA et al. The text discusses the need to develop a system that allows the UAV to be fully independent and suggests two ways to achieve this: determining the number of solar cells used or increasing the capacity of the batteries. It also mentions the potential of paragliding to extend flight time and the importance of creating a detailed simulation model for specific flight scenarios and conditions. Additionally, the text highlights the components of the power supply system for UAVs, such as solar cells, charge controllers, battery cells, and the building management system [62].
Wael Jaafar et al. surrounded the relationship between power, battery dynamics, and the operation of a laser-charged four-wheel drive UAV. The authors emphasize the importance of considering the battery perspective in drone-related challenges such as route planning and resource optimization. They propose reevaluating the traditional energy perspective and evaluating energy as a function of the drone's movement system. The paper also discusses techniques for prolonging drone missions, including recharging using a low-power laser source and accurately estimating power consumption. The authors use graph theory approaches to solve the path planning problem, they find that the traditional energy perspective is conservative and propose an adjustment method to evaluate energy better. Finally, the influence of factors like turbulence and distance on the charging source is studied. The authors plan to validate their results through actual tests [63].
Steven R. Anton et al. develop wing include piezoelectric layers for power generation and thin-film batteries for energy storage. The text describes the electromechanical modeling and experimental testing of the wing, as well as its ability to harvest and store electrical energy simultaneously. The potential applications of this technology in UAVs are also discussed [64].
Parvathy Rajendran et al, this paper presents a new mathematical design model for UAVs, that enhances their performance for long-duration missions. The model was verified and demonstrated a 25% decrease in power consumption compared to previous UAVs. The study also examined the differences between solar and nonsolar-powered UAVs, revealing that while they UAVs can carry more payload, they have limited endurance [65].
IV. RESULTS AND DISCUSSION
The paper explores various strategies and technologies to overcome the limitations of drone battery capacity. It delves into energy consumption analysis during flight, power loss components, and methods to optimize energy harvesting. Notable contributions include advancements in AI-based fault detection, vibrational stabilization models, and design optimization for improved efficiency. Additionally, the integration of piezoelectric and solar energy harvesting, wireless charging systems, and hybrid power sources was discussed. The study emphasizes the importance of energy-efficient path planning, powertrain designs, and innovative solutions like the L-shaped energy harvester. Overall, it highlights various approaches to enhance drone endurance and performance across different applications.
V. CONCLUSIONS
In conclusion, the surge in drone applications across diverse industries has been accompanied by challenges, particularly in addressing limited battery capacity. Integrating artificial intelligence and mechatronics has played a pivotal role in transforming drones into cost-effective, user-friendly, safe, and environmentally friendly options. Various studies propose innovative solutions to optimize energy harvesting from UAV body vibrations and extend flight durations.
Power loss analysis during flight underscores the importance of understanding mechanical, magnetic, iron, and copper losses. Energy consumption calculations, battery storage, and the percentage of energy consumption during flight provide a comprehensive overview. Diverse UAV power harvesting methods, such as design improvements, stability considerations, vibration analysis, and propulsion system optimization, showcase the depth of research in this field.
Exploring energy generation strategies encompasses piezoelectric harvesting, wind energy utilization, solar-powered UAVs, and hybrid systems combining different power sources. Each approach presents unique benefits and challenges, highlighting the need for a nuanced understanding of power generation for sustained drone operations.
Electrical circuit generation studies delve into wireless charging systems, communication-enabled energy delivery, and optimizing harvested energy for UAVs. These advancements aim to overcome energy constraints, enhance efficiency, and provide a seamless power supply for drones.
The paper concludes by emphasizing the significance of ongoing research in developing statistical models for renewable energy harvesting, exploring new power sources like supercapacitors, and proposing innovative solutions such as laser charging and multifunctional composite power collectors. The comprehensive analysis presented in this paper underscores the interdisciplinary nature of drone technology, encouraging further exploration and refinement of these strategies for the future of UAVs.
The recommendations based on the presented research are as follows:
Enhance integration between artificial intelligence techniques and vibration data collection to enable real-time fault detection, improving the performance of UAVs.
Support research using optimized design to enhance the structural and vibrational efficiency of crucial components such as wings and engines.
Explore the feasibility of utilizing piezoelectric technologies for energy harvesting from multiple vibration sources to enhance the power efficiency of UAV systems.
Encourage further research into integrating wireless charging systems and optimizing solar energy utilization to extend the flight capabilities of UAVs.
Support ongoing research into efficient energy models for path planning, minimizing energy consumption during missions.
Promote battery technology research and performance enhancement techniques to achieve progress in increasing the capacity of UAV batteries.
Advocate for continued analysis of the advantages and challenges of hybrid energy systems to maximize the benefits of multiple power sources.
Encourage research into energy harvesting technologies from diverse environmental sources such as wind and solar to improve endurance and mission sustainability.
These recommendations aim to foster innovative technologies and improve the performance of UAVs through a comprehensive set of technical innovations and engineering concepts.