I. INTRODUCTION
Various haptic communication systems have been designed and developed by researchers over the years in order to integrate the touch channel in digital communication. These systems aim to enhance physical intimacy during remote interaction between people by stimulating the haptic sensations of hugging [3], [7], [23], [33], [49], handshaking [1], [31], [36], hand holding [2], [10], [34], kissing [16], [47], [55] and other forms of interpersonal touch [37], [43], [52].
Our everyday communication devices, such as mobile phones, present most information through the visual and audio channels. Haptic stimulation is used in the form of vibration that is only able to present Somewhat binary information. This type of discriminative touch, which is used for information processing, engages different receptors and neural pathways from affective touch, which is used in social communication and emotional expression , . There is an extensive amount of research revealing the important role of affective touch in increasing positive social behaviours (the Midas Touch effect) , building bonds , and communicating emotions in human interaction. Affective touch also has effects on our physiological measures, indicating a more innate and universal link between haptic stimulation and physical wellbeing. More specifically, intimate contact like stroking, hugging, kissing and hand holding can decrease stress hormones and decrease blood pressure in both adults and infants , , , .
In the case where touch is mediated through digital systems where the interaction between partners is remote, similar effects as those of direct physical touch aforementioned can be observed. In a study of the Midas Touch effect in virtual touch condition, a higher percentage of participants displayed helpful behaviour when vibrations were given on their arms compared to no vibration [11]. Numerous quantitative and qualitative user studies conducted on telehaptic systems have found that mediated touch using various stimuli including vibration, pressure, friction and warmth can enhance the sense of physical presence and intimacy, elicit positive emotions, and express affections and emotions [3], [10], [37], [40], [41], [44], [46], [49]. On the physiological level, there is evidence showing that hugging a human-shaped telepresence medium reduces stress hormones and increases positive feelings for the conversational partner [45].
It is not hard to identify a gap between research and industrial applications in haptic technologies for communication. Although a plethora of research has provided convincing evidence of the benefits of using touch as a communication channel in remote interaction, and a wide range of design frameworks and prototypes, there are very few commercial solutions available on the market. Among those, the HugShirt and Tjacket are examples of commercial wearable garments that can send simulated hugs through the Internet. Other haptic devices aim to augment communication by adding an extra sensory dimension to the touch screen and vibrations of mobile phones. For example, Smart- stones Touch is a pebble-shaped Bluetooth device that recognises simple touch and gestures, and send them as messages which the users assigned to the gestures. However, most of these devices still use vibration motors to generate tactile sensations on users' skin, which can hardly reproduce the realistic feelings of a human touch. On the other hand, recent haptic technology implemented in mobile devices is moving towards precise force feedback to touch events rather than the traditional vibration output. Apple's Taptic Engine found in devices such as Apple Watch and iPhone 7 likely uses Linear Resonant Actuators (LRA) instead of Eccentric Rotating Mass (ERM) vibration motors to give a more precise level of linear force feedback that matches the amount of pressure applied by the user .
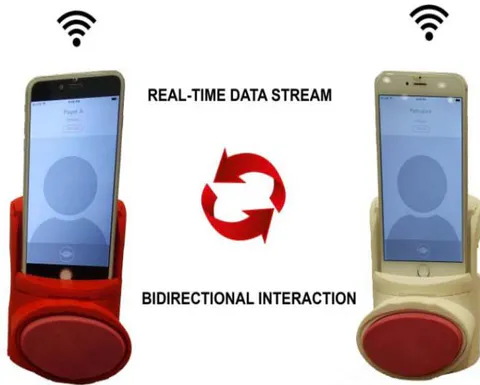
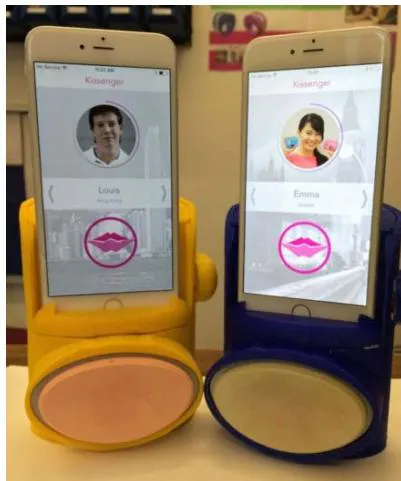
The goal of this paper is to provide a design guideline using off-the-shelf components, detailed implementation and a Turing test evaluation of a haptic kissing device for mobile phones. This internet kiss messenger, nicknamed the "Henry Kissenger" machine, can sense accurate lip pressure and transmit haptic sensations of kissing through linear force-feedback when attached to mobile phones. The touch interface consists of a flexible lip surface and an array of force sensors and linear actuators. Figure 1 shows a pair of the "Henry Kissenger" machines. This research focuses on perpendicular force stimulation on the skin, as it is the most effective and preferable type of stimulation in conveying pressure sensations compared to tangential force and vibrotactile stimulation [32].
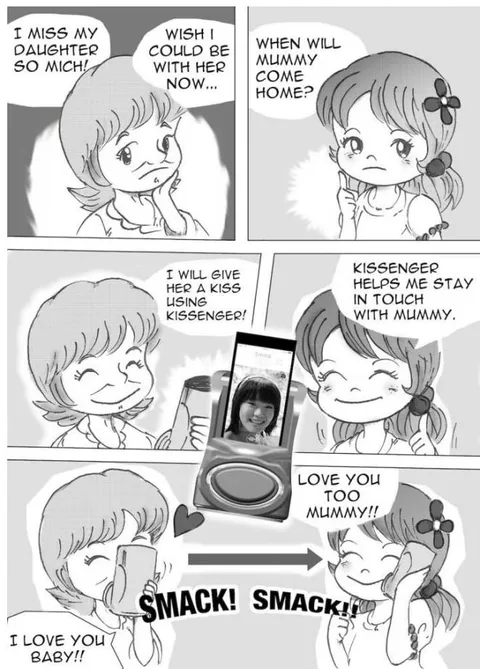
The kissing machine is designed to enhance intimacy and emotional connection in digital communication, allowing families and friends to physically interact with each other over the Internet. One such scenario is depicted in Figure 2. This device is evolved from previous versions of Kissenger, which is a work conceived by the author from the idea conceptualisation stage almost ten years ago [42].
Figure 3 shows two earlier versions of Kissenger developed in our lab, both required to be connected to a computer for data transmission. The device presented in this paper is the first Internet kissing machine that works with mobile phones. Unlike many haptic communication systems that adopt a metaphorical approach of using vibration patterns or warmth to represent physical touch, this system measures the exact pressure applied by the user at various points over a surface area and uses dynamic normal force stimulation to transmit realistic sensations of kissing. We also consider the industrial aspects of force-feedback haptic technologies for communication. Many of the existing research prototypes are unsuitable to be made into consumer products due to their bulkiness, high production cost, and inability to be to be integrated with everyday communication devices. We recognise that the key to advancing into the "Multisensory Age" of Internet communication is to first integrate high fidelity haptics into all kinds of devices. Taking its size, power consumption and production cost into account, we aim to design and build a haptic device for mobile phones since they are the most commonly used communication tool.
Lastly, we report the findings of three in-depth experiments of the Kissenger machine. Experiment 1 compared participants' ratings of pleasure, arousal, and user experience for mediated kissing with those for real kissing in a lab setting. Experiment 2 is a unique embodied Turing test that investigates the effects of haptic kiss communication in an Imitation Game. In experiment 3, we compared the relationship satisfaction and perceived stress levels of long distance couples who used Kissenger for one week to those who did not use Kissenger.
This paper presents groundbreaking studies and results that have never been published before in our papers , , . In Experiment 2 (the Haptic Imitation Game), we have an improved experimental design and a larger sample size of 100, as compared to 20 in our previous experiment . Our new results show that interrogators have a higher chance of winning the Imitation Game when they use the kissing device, which suggests that haptic information transmitted through remote touch plays an important role in the Turing test.
The key novelties and contributions of the paper are high-lighted as follows:
Design, implementation and evaluation of a novel haptic kissing device for mobile phones, which uses dynamic normal force stimulation to transmit realistic sensations of kissing in order to enhance intimacy and emotional connection of digital communication.
Analysis of the industrial aspects of force-feedback hap-tic technologies in communication. Presenting a design framework for building commercialisable high fidelity haptic devices using off-the-shelf components, and capable of integrating with everyday communication devices.
A unique academic study of remote haptic communication, which is an embodied Turing test in the form of the Imitation Game originally proposed by Alan Turing, modified to include the haptic kissing device to study the effects of remote haptic kissing on the winning rate of the players in the game. This is also believed to be the first mutual haptic kissing between humans and machines studied in literature.
Quantitative analysis of a laboratory experiment comparing mediated kissing vs real kissing, as well as a field study involving the use of Kissenger by long distance couples in real life.
II. SYSTEM DESIGN
The haptic kissing communication system consists of three main parts: the hardware devices, the software application and data communication.
a) Hardware Development
i. Actuator Selection
Actuators are the central elements of a haptic system as they largely determine the power requirements, control principles, aesthetic design and most importantly the haptic quality of the system. The kissing device is required to generate a range of localised normal force stimulation, which simulates kissing sensations by creating palpable pressure and skin indentation on the human lips. The selection criteria that have been considered are the type of actuator, output force, stroke, size, driving voltage and power consumption of the actuators.
Most commercial haptic interfaces for mobile devices provide global or localised vibrotactile feedback. Eccentric Rotating Mass (ERM) vibration motors are typically used in mobile phones due to their low power consumption, compact size and low cost. More recently, Linear Resonant Actuators (LRA) replaced the ERM motors in some devices to produce better haptic effects. Compared to ERM motors, LRA has 50% less power consumption, twice the output force, and faster response and braking time. LRA is also able to produce an impression of linear force-feedback as it vibrates vertically in a single axis. Nevertheless, LRA does not give positional displacements and the output force is insufficient to convey realistic lip pressure.
Linear motions can be achieved by converting rotary electric motors using linear components such as toothed belts, pulleys, lead screws or ball screws or other mechanical converters. There are also self-contained linear actuators that provide direct linear motion, but they typically have a larger footprint and not suitable for applications which size is a main issue. Linear stepper motors are good for precise positioning systems, and is available in captive, non-captive and external linear configurations . A captive linear actuator is the most suitable for the kissing device as it has a compact form factor with a built in mechanism that prevents the rotation of the shaft, allowing it to extend and contract linearly without any external elements.
Several other types of actuators such as piezoelectric actuators, pneumatic actuators and shape memory alloy (SMA) actuators are also some popular choices for linear motion applications. Piezoelectric or ultrasonic actuators come in miniature packages, often used in tactile display systems or Braille devices . They benefit from high precision, fast response, low power consumption and small footprint, but they typically have short strokes and low output force, and they require high driving voltage in the range of 50V-200V, hence they are not suitable for battery powered devices.
Pneumatic cylinders can generate linear motion with high speed and force with low initial costs. However, these actuators can only travel the full stroke lengths and it is difficult to control precise positions. They also require additional valves and air compressors to operate, making the whole system bulky and noisy overall.
SMA actuators have the advantages of being flexible, lightweight, noiseless and low power consumption. They are essentially a piece of wire with shape memory property, and are able to generate linear motions by changing the temperature of the shape memory element. This can be achieved by controlling the current that flows through the wire. An example of a commercial SMA actuator is the Flexinol wire , which expands and contracts like muscles with current. SMA actuators are used in haptic displays with pin arrays such as Lumen [39]. Users can touch and interact with the haptic display that consists of an array of finger-sized, cylindrical pins pushed up and down by SMA wires. Due to the properties of SMA, the wires can only generate two different positions, and have a slow deactuation response as the material takes time for cooling. Another drawback is that SMA actuators are unable to generate enough output force, hence unsuitable for our system.
Table 1 shows a comparison of the different types of linear actuators mentioned above. It lists the advantages and disadvantages of each actuator, and provides an off-the-shelf option which is suitable to be integrated in small size haptic communication systems that require linear force-feedback stimulation. For applications in general haptic systems, Haus et al provides an aid for actuator selection based on the system dynamics, which includes a wider range of actuator principles [15].
ii. Sensor Selection
This system requires force sensors to measure the force applied by the users' lips to the device. Load cells, strain gauges, piezoresistive force sensors and piezoelectric force sensors are some types of force sensors to choose from. The hardware design, accuracy, range and resolution need to be considered in choosing the type of sensors to use in the system. A strain gauge measures force by converting the deformation of a material caused by applied force to electrical output. It is highly accurate but requires complicated conditioning circuits and has to be mounted on some flexible mechanical structure that converts force to strain, usually a cantilever beam. A load cell is a readily available component that comprises a strain gauge mounted on a bending beam. However it is generally bulky and not suitable for OEM/design in applications .
A piezoelectric force sensor is made of a piezoelectric ceramic disk which generates a voltage when subjected to force or strain. Piezoelectric sensors are suitable for measuring highly dynamic forces like oscillations or vibrations due to their fast response. They are cost efficient and long lasting, but on the other hand they are also sensitive to noise, light and heat, making them difficult to control.
Piezoresistive force sensors, also known as force sensing resistors (FSR), have become increasingly common and are found in many applications. The resistance of a FSR varies linearly with the force applied to its sensing area. To be more precise, a FSR measures pressure as the output depends on the surface area that the force is applied. These sensors are made from a special piezoresistive material sandwiched between two pieces of flexible plastic sheets with printed conductors on each inner half . The advantages of FSRs are that they are flexible, thin, light, inexpensive, require minimal driving circuitry and have higher resolution than strain gauges. They are very sensitive to human touch and have a customizable measuring force range by changing the value of the feedback resistor used in the driving circuit. FSRs come readily available in various lengths, sensing areas or custom designs that include multiple sensing elements, making them suitable for many types of haptic applications.
iii. Control Structure
Force-feedback control schemes can be classified into two types, admittance-control and impedance-control . Impedance-controlled systems take motion as input and produce force output. Admittance-controlled systems take force as input and output as motions, defined by kinematic measures such as position, velocity and acceleration. Admittance control is typically used in cooperative teleoperation systems and haptic displays such as the FEELEX system [20], which uses pin arrays to simulate spatial tactile patterns and surface textures or shapes of virtual objects through force-feedback. In this system, surface deformation is generated by a 6x6 linear actuator array underneath a piece of rubber sponge. Palpable haptic sensations are produced by the up and down motions of the linear actuators. Two strain gauges are placed on top of each actuator to measure the force applied by the user's hand.
| Actuator Type | Stimulation | Advantages | Disadvantages | Off-the-shelf Option |
| Linear Resonant Actuator (LRA) | Linear vibrotactile | Low cost and very low powerLow drive voltage, typically 2V (RMS)Small size, available in coin shape typically 8-10mm diameters | Does not generate a wide range of linear force feedback, no positional displacementLow output force but higher than ERM vibration motors | 8mm Linear Resonant Actuator by Precision Microdrives, 1.8V, 0.095W, 9 USDa |
| Servo motor | Linear and rotary | Closed loop positioningSuitable for high speed and heavy loads | Typically more expensive than stepper motors | PQ12-R Micro Linear Servos for RC & Arduino by Actuonix Motion Devices, 21mm x 36mm, 15g, 6V, 3.3W, stroke length 20mm, max output force 50N, 70 USDb |
| Stepper motor | Linear and rotary | Open-loop positioning, no encoder requiredHolds its position without overheatingSuitable for low speed, light and dynamic loads | No positional feedback if load exceeds output torque | 15000 Series Can-stack Linear Actuator (Captive) by HaydonKerk, 15mm x 40mm, 28g, 5V, 1.6W, stroke length 12.7mm, max output force 32N, 80 USDc |
| Piezoelectric | Linear and rotary | High precisionFast response time and high speedVery low power | High drive voltage, typically 50-200VShort stroke and output forceExpensive | N-412 Fast Linear Actuator with PIShift Piezomotor by PI, 15mm x 58mm, 25g, 48V, stroke length 13mm, max output 10Nd |
| Pneumatic | Linear | Low initial costHigh force and speedHolds its position without additional power | No precise position control except at end of strokesRequires valve and air compressor - bulky, noisy setupRequires regular maintenance | Double Action Pneumatic Pin Cylinder by SMC, 16mm x 48mm, stroke 15mm, 21g, 35 USDe |
| Shape memory alloy | Linear | Flexible and very compactNo complicated driving circuit required | Low output forceDifficult to control precise positionSlow response time | FLEXINOL Actuator Wiref |
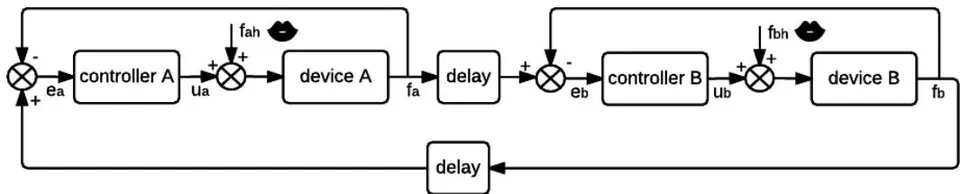
Kissenger is a bilateral telehaptic system based on admittance control, as it measures force from users' lips and controls the actuator position. Different from conventional master-slave systems in which one side of the system is passive, this system is completely symmetrical as both sides are masters and slaves. The objective of the controller in each device is to synchronise the contact force between the user and the haptic device on both sides of the system at any given time. In a perfectly transparent bilateral control system, the law of action and reaction must be realized, hence the net force should be zero. The controller objective can be expressed as follows:
Where and are the measured contact forces between the user and the haptic device on each side of the system.
Each actuator changes its position to compensate the difference between and . When , the actuator in A's device will move towards the user to increase the contact force. When , the actuator will move away from the user to reduce the contact force. The position of the actuator is controlled by a local force controller which aims to
(1) equalise and . The dynamics of the system can be modelled as a simple spring system where the positional change is proportional to the amount of force applied. The spring constant determines the perceived stiffness of the haptic interface. The value of depends on the resolution and sensitivity of the force sensors, as well as the stroke length and output force of the linear actuators. The parameter is tuned to produce the same magnitude of force to both users. The position of an actuator relates to the difference of the two contact forces by a proportional gain, as given by the following equation:
Figure 4 shows a block diagram of the bilateral force controller. The control system is symmetrical as both users are supplying active inputs to the system. The constants are tuned depending on the linear properties of the force sensor derived from calibration, the maximum stroke length of the linear actuator as well as the perceived stiffness of the haptic interface. Upper and lower limits of the actuator position are imposed by the stroke length of the actuator.
b) Software Application
Developing haptic devices for mobile phone not only expands the haptic channel for mobile communication, but also enables the devices to interface with other mobile applications, and access the hardware and software functions of the mobile phone.
For example, the haptic device can transmit and receive real-time data through the Internet by connecting to the mobile phone, saving the need of an inbuilt Wi-Fi module. Users could also interact with each other through video or audio calls using their mobile phones while using the haptic device, making it a multisensory
Internet communication experience. By interfacing with other social applications such as Skype, Facebook or Whatsapp, touch communication with the haptic device could be spread among a vast social network, not just between two individuals.
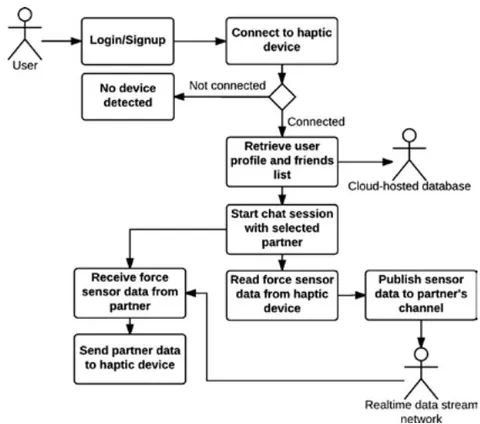
A mobile application is required for connecting the haptic device to mobile phone, and transmitting data through the Internet in real-time. Communication between the device and mobile phone can be established wirelessly, using Bluetooth Low Energy (BLE) for example, or wired through USB or audio cable. BLE connection requires a BLE module embedded in the haptic device, increasing the production cost of the device and power consumption of the phone. With the wired option, the gadget can be designed as an attachment to the mobile phone just like the Kissenger device. Real-time sensor data is transmitted between the haptic device and mobile application, which then transmits it over the communication network to other users. Figure 5 shows the activity diagram of a typical user session with the haptic kissing device for the mobile application. Latency, bandwidth and packet losses should be considered in both stages of the data transmission process.
c) Network Architecture
The two fundamental network architectures for remote haptic systems are the client-server architecture, and the distributed peer-to-peer architecture. Other hybrid models have also been proposed but not widely used . The client-server model has the advantage of maintaining high consistency among all client devices, as all haptic simulations and force calculations are processed in a centralised server. However this approach lacks in responsiveness, increasing the latency and instabilities in haptic interactions between clients. On the other hand, the peer-to-peer architecture provides high responsiveness, as each client device has a local controller that renders the haptic stimulation, updates and processes data to/from other peers . This architecture is most commonly used in collaborative haptic systems due to its responsiveness and scalability.
III. SYSTEM IMPLEMENTATION
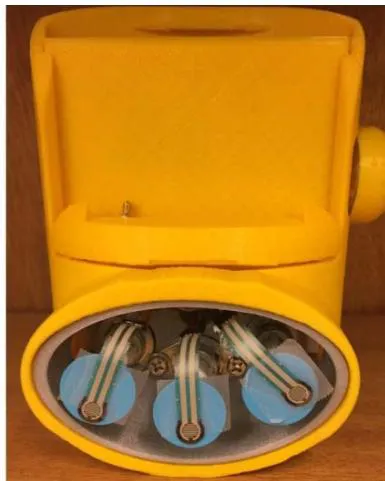
A pair of prototypes of the Kissenger device was designed and implemented for iPhone. The hardware device consists of three sets of captive linear stepper motors (Haydon Kerk 19000 series) and force sensor resistors (FSR400 5mm) evenly distributed under a soft and flexible lip-like surface. A low voltage stepper motor driver (Texas Instrument DRV8834) is used to drive each motor in microstepping mode. An Arduino Pro Mini microcontroller is embedded in the device for force control. A RGB LED is also placed under the lip surface to give a visual feedback to the kiss interaction. Users can also change colours on their partner's device to convey their emotions and feelings. The device was designed to attach to the mobile phone as a haptic telepresence device, such that users could see the face of their partner through the mobile application while kissing on the lip-like haptic interface in real-time. The picture on the left of Figure 6 shows a pair of Kissenger devices connected to iPhone 6 Plus running the Kissenger mobile application, and the picture on the right shows the internal mechanism of the lip sensing area.
Proper mounting techniques ensure an accurate and repeatable measurement using force sensitive resistors. The sensing area should be mounted on a flat solid surface without bending, and the applied force should distribute evenly over the entire sensing area . A circular support is attached on top of the shaft of the linear stepper motor for the sensing area of the FSR to rest on. Additionally, a thin circular puck about the same size as the sensing area is placed on top of the sensing area so that the force exerted on the lip cover can be better registered by the sensor.
The microcontroller in the device reads the force data measured by the FSRs and sends it to iPhone via a FSK modem on a polling basis. The data is modulated to 4900Hz for a low bit and 7350 Hz for a high bit and sent to the connected mobile phone through the microphone channel of the audio line. Similarly, force data received from the partner's device is also transmitted from the iPhone to the microcontroller via a FSK modem for processing. The hardware device is powered by a 6V DC power supply. This low input voltage easily allows the device to be battery powered.
A Kissenger mobile application for iOS was developed for users to connect and interact with the hardware device when plugged into the phone. The application implements real-time data transmission between users using the Pubnub data streaming service. A subscribe-publish model is used for real-time data streaming. Each client device has its own dedicated channel with a unique publish and subscribe key. A client always subscribes to its own channel to receive the messages sent to it. When two remote clients establish a connection through the application, they exchange the publish key of their designated channels and each client publishes real-time data to the partner's channel. The subscribing client always listens to its channel and receives only the messages published onto the channel. Some key features of the mobile application include video chat, changing the LED colour of a partner's device and connection to social networks. The application allows users to remotely kiss their loved ones over the Internet during a video chat, creating a more intense sense of telepresence.
IV. EXPERIMENT ONE: REAL KISSING VS MEDIATED KISSING
An experiment was carried out to assess the effectiveness of the Henry Kissenger machine by comparing mediated kissing to real kissing. The objective of the experiment was to qualitatively measure various aspects of human kissing and mediated kissing carried out through a questionnaire based on the semantic differential method. By comparing participants' ratings for their kissing experience in the mediated and non-mediated conditions, we examined whether the Henry Kissenger machine could effectively simulate physical kissing over a distance.
A semantic differential questionnaire was devised for assessing participants' affective responses to the two different modes of kissing. The semantic differential (SD) scale is commonly used to measure affective responses and attitudes to events, objects or concepts. It is typically represented on a 7-point rating scale with bipolar adjectives, such as 'unhappy/happy' and 'unpleasant/pleasant', at each end of the scale. The word pairs used in the questionnaire administered in our experiment were extracted from two existing SD scales — the 18-item Semantic Differential Scale by Mehrabian and Russell [30], which measures emotional responses on the dimensions of pleasure, arousal, and dominance, and Hassenzahl's AttrakDiff questionnaire [12], which assesses the hedonic and pragmatic qualities of user experience. The questionnaire in this experiment contained 12 pairs of bipolar adjectives that measure the emotional dimensions of pleasure and arousal, and the self-evaluated experience of the kiss during the experiment. Items included 'annoyed/pleased', 'unaroused/aroused', 'technical/human', etc. Each item was rated on a 7-point scale (-3 to 3).
a) Participants
50 consenting couples, ages ranged from 19 to 57, were recruited to participate in the study. 18 couples were married and 32 couples were in a romantic relationship. The couples were randomly assigned to two groups, experimental group and control group. Each group consisted of 25 couples.
b) Experimental Procedures
The control group participated in the real-kiss (non-mediated) condition, where participants kissed their partners directly on the lips. After an initial briefing and signing the consent forms, each couple was led to a completely dark room with no light source. They were given one minute alone in the room to kiss each other by touching their lips with their mouths closed. Participants were brought out of the dark room at the end of one minute, and were asked to rate the emotional responses and experience of their kiss by completing the semantic differential questionnaire individually. The experiment took place in a dark room as we wanted participants to focus on touch sensations rather than visuals during their kiss. Participants were instructed to close their lips while kissing so that the real kiss and the mediated kiss were carried out through the transmission of lip pressure only.
Couples in the experimental group were assigned to participate in mediated kissing using the Henry Kissenger device. A pair of Kissenger devices was configured to connect to each other before the experiment. During the initial briefing, the experimenters demonstrated to the participants how to use the kissing device to kiss someone remotely. Each participant was then given a kissing device to familiarise themselves with it and to try out with their partner with the help of the experimenters. After ensuring that the couple could correctly use the kissing device to kiss each other, each person was led to a separate dark room with the same conditions, and was asked to use the device to kiss their partner in the other room for one minute. At the end of the experiment, participants completed the same questionnaire to evaluate their kissing experience and emotional responses. Participants in both groups had complete privacy during their kiss, and they were not recorded or observed in any way by the experimenters.
c) Results and Discussion
The means and standard deviations of ratings on the semantic differential questionnaire were calculated for each of the 12 attributes for both groups. Aggregated values were also obtained for the 3 dimensions assessed by the questionnaire — pleasure, arousal and user experience. A Mann-Whitney U test for independent random sampling ( ) was conducted to assess for significant differences between the experimental group and control group.
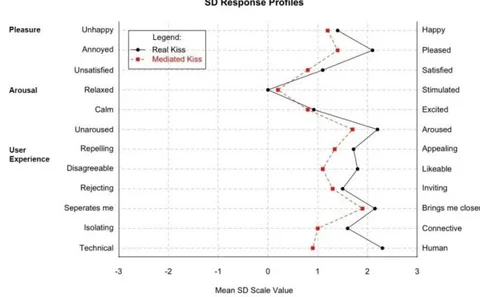
Figure 7 demonstrates the mean values of each semantic differential descriptor calculated from the results of the questionnaire completed by participants in the experimental group and the control group. Statistical analysis did not reveal any significant difference between the real kiss and mediated kiss conditions for ratings of pleasure (z = 1:216, p < 0:05), arousal (z = 0:536, p < 0:05), and user experience (z = 1:906, p < 0:05).
When comparing the mean values, the real kiss group gave higher ratings on all three dimensions than the mediated kiss group in general, although this difference is not statistically significant. For most bipolar descriptors, the differences of the mean values between two conditions are within 10%. This shows that the affect elicited by the Henry Kissenger machine is very similar to that elicited by human kissing. On the 'technical/human' spectrum, the real-kiss group scored a relatively higher mean (M = 2:33) compared to the mediated-kiss group (M = 0:91). The result is not surprising as the current prototype still has its technical limitations in reproducing all aspects of a human kiss. Further improvements in material, fidelity, and appearance of the kissing machine are expected to improve the "humanness" of mediated kissing.
V. EXPERIMENT TWO: THE HAPTIC IMITATION GAME
The purpose of the study is to investigate the effect of the kissing device on the winning rate of the players in the Imitation Game. Alan Turing depicted the Imitation Game in 1950 as a way to examine whether machines have the ability to think [50]. The game led its way to the Turing test, which has been widely used as a standardised test for machine intelligence.
This game consists of three players: A is a male, B is a female and C is the judge. Player C is unable to see or hear Player A and B, he/she can only chat with Player A and B by typing on a computer. Player C asks questions from both Player A and Player B (henceforth referred to as expert players) to determine which of them is female. Both expert players would attempt to convince Player C that they are female during the game. Player C wins the game if he/she can correctly identify the female player.
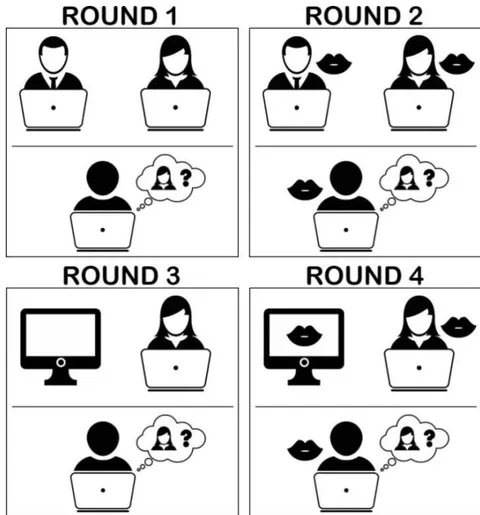
In this study, we followed the original Imitation Game described by Alan Turing in his paper as closely as possible, with the exception of introducing a haptic element by using the Kissenger machine. Participants played the role of interrogators in the experiment, and their objective was to ask the expert players questions in order to identify the female player. The experiment consisted of four rounds of game, and the duration of each round was 5 minutes. During each round, participants chatted with two trained expert players separately in two online chat rooms. In two of the four rounds, participants chatted with two humans with and without the kissing device. In the remaining two rounds, a chatbot replaced the male player as the expert player, and participants played the game with a chatbot and a human with and without kissing. Figure 8 illustrates the four different conditions of the study.
In this study, participants are considered to have won the game if they had correctly identified the female player. We hypothesized that participants would be more likely to win the Imitation Game when they use the kissing machine during the conversation than when no kiss interaction is involved. We expect similar effects of the kissing machine for both human and chatbot expert players.
a) Participants
100 undergraduate students, aged 18-25, participated in the experiment after signing the informed consent form. 57 participants were male and 43 of them were female. As our experiment was conducted in a Muslim country and the majority of the participants were Muslims, we were required to be concerned about Muslim religious rules. No participants expressed religious concerns to using the kissing device to remotely kiss an unknown person of either gender.
b) Chatbot
The chatbot adopts the open AIML architecture and the knowledge base from the Artificial Intelligence Entity, or ALICE. It is built on an existing implementation through Program AB, and a Java programming language interpreter for AIML, an XML-compliant language for authoring chatbots. We modified and extended the categories in ALICE by making some of the responses more humanlike, and creating new categories targeted at the Imitation Game. For example, we added questions such as "What is your favourite fashion brand?", and "Do you like shopping?", to which the chatbot would answer "Simple and classy" and "Of course" etc. We aim to provide a natural open-domain conversation without limiting the topics that can be discussed.
Although the chatbot replaces the role of the male player in the game, its goal is to convince the interrogator that it is female. Two female personae are built by assigning gender-specific attributes, which include name: Eva, firstname: Eva, middlename: Tay, lastname: Lee, fullname: Eva Tay Lee, gender: female, boyfriend: Olando, job: Marketing executive, skills: cooking, writing and skiing etc. As the identities of the expert players should be different in each round, the attributes and preferences of the chatbot are different in round 3 and round 4. Furthermore, a time delay proportional to the length of the response is added before displaying each reply to the human participants in order to simulate the typing time required by humans.
The chatbot is deployed as a Representational State Transfer (REST- FUL) web service and through a web-based chat interface that we developed for the users to converse with it. The transcript below shows an example of a chat session between a participant and the chatbot.
Human: hey
Chatbot: Hi! It's delightful to chat with you.
Human: how are you?
Chatbot: Feeling really joyful today.
Human: are you ready for a kiss??
Chatbot: Sure
Chatbot: Say Ok when you are ready
Human: ok
Chatbot: Hmmmmmm...i feel the sensation
Human: sure?
Chatbot: Oh.
Human: do you like shopping??
Chatbot: I like shopping of course
Human: ok
Chatbot: Hmm.
c) Experimental Procedure
The expert players and the chatbot were assigned the roles of Player A and Player B in every round. The assignments of Player A and Player B are as follows: round 1: Player A was the male and Player B was the female; round 2: Player A was the female and Player B was the male; round 3 and 4: Player A was the chatbot and Player B was the female. The kissing machine was used in round 2 and round 4 only. The role assignments for all 4 rounds are summarised in Table 2.
| Player A | Player B | |
| Round 1 | Male | Female |
| Round 2 | Female + Kissing device | Male + Kissing device |
| Round 3 | Chatbot | Female |
| Round 4 | Chatbot + Kissing device | Female + Kissing device |
Participants were brought to a quiet lab room and asked to sit in front of a laptop, which showed two online chat rooms side by side. The names of the expert players displayed in the chat rooms were "Player A" and "Player B" respectively. The experimenter explained the experimental procedure to each participant before the beginning of the experiment, and asked the participant to fill in the demographic questions in the questionnaire. Participants were instructed to initiate the chats with both expert players and ask them questions to identify their gender. The conversations were open-domain, ie. participants were not restricted to the type of questions or topics they could discuss. At the beginning of each round, the experimenter started a timer for 5 minutes and left the participant alone in the room. When the time was up, the experimenter informed the participant to stop the chat and write down the answer for who the female player is for that round in the questionnaire. No time limit was given for answering the questionnaire.
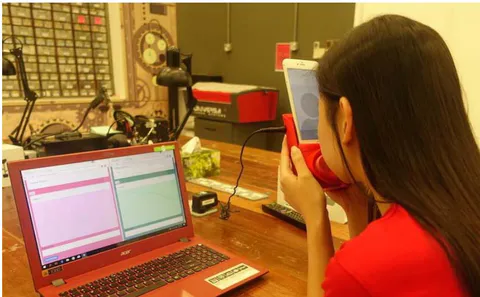
Before the start of round 2 and round 4, participants were presented with a pair of kissing machines each connected to an iPhone 6 Plus. Each device was connected to one of the expert players' kissing device through the mobile application developed. The mobile application displayed "Player A" or "Player B" depending on which player it was connected to. The experimenter explained the functions of the kissing device and demonstrated how to use it to remotely kiss the expert players. Participants were allowed to try out the device to ensure that they could use it themselves. The lip sensing surface of the kissing device was cleaned and disinfected with isopropyl alcohol before every use. Participants were told to initiate the kiss in the chat with each expert player in whatever way they felt comfortable with, at least once during the round. Figure 9 shows a participant using the haptic kissing device during the game.
In order to minimize the learning and inference effects across conditions, we randomized the order of the rounds for each participant. Expert players were also instructed to adopt a different character and answering style in each round with the same participant. Similarly, the participants were also told that they were chatting with two different human players in each round. In round 3 and round 4, the involvement of a chatbot was not made known to the participants.
d) Results and Discussions
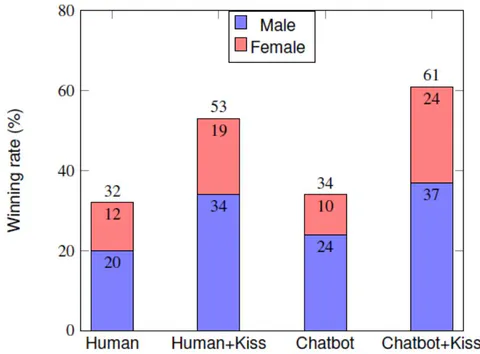
When both expert players are humans, 34 participants (24 males, 10 females) correctly identified the female player without the kissing device, and 61 participants (37 males, 24 females) had the correct answer with the kissing device. According to our hypothesis, we expect the winning odds of participants who used the kissing machine to be higher than those who did not use the kissing device. A binary logistic regression model was used to predict the odds, which is expressed as:
where if kissing device was used, if no kissing device was used. The log-odds of a randomly chosen participant winning the game is for no kissing device used, and for kissing device used.
Statistics showed that the use of the kissing device had a significant effect on the odds of a participant making the correct guess. Participants who used the kissing machine during the conversation with both human expert players were 3.11 times (Odds ratio = 3.11) more likely to win the game than when they did not use the kissing machine (Exp(B) = 0:321, B=-1:135, SE=0:298, p<0:05). It was also found that the participant's gender had a significant effect on their winning odds. Male participants were 1.84 times (Odds ratio = 1.84) more likely to make the correct guess than female participants (Exp(B) = 0:542, B=-0:612, SE=0:302, p=<0:05).
When the chatbot acted as the male expert player, 32 participants (20 males, 12 females) successfully identified the female player without the kissing device, and 53 participants (34 males, 19 females) won the game with the kissing device. Comparing the results between the kiss and no-kiss conditions, it was found that the kissing device also had a significant effect on the winning odds of the interrogators. Statistics showed that participants who used the kissing device during the conversation were 2.42 times (Odds ratio = 2.42) more likely to win the game than when they did not use the device (Exp(B) = 0:412, B = -0:886, SE = 0:296, p < 0:05). However, the participant's gender had no significant effect on the winning odds (p = 0:102).
The results of the study supported our hypothesis that interrogators have a higher chance of winning the Imitation Game when they use the kissing device than when no kiss interaction is involved. This suggests that other than language and reasoning, haptic information transmitted through remote touch also plays an important role in the Turing test. The original Turing test measures machine intelligence based on the natural language ability of the machine alone. Rapid advances and higher requirements in AI and Robotics research are proving it difficult for the Turing test to be a sufficient benchmark to measure all aspects of intelligence. In the field of human-robot intimate relationships in particular, physical embodiment and touch interaction are some of the key elements that determine the perceived intelligence of a robot partner. A new form of Turing test is required to measure a machine's ability to perceive the physical environment, to perform and to understand the physical actions of humans [35].
VI. EXPERIMENT THREE: EFFECTS ON LONG DISTANCE RELATIONSHIPS
In the last study, we aim to explore the effects of Kissenger on the relationship satisfaction and psychological well-being of couples in long distance relationships over a period of one week.
Previous studies suggest that kissing has positive physiological and psychological health effects on individuals. In a 6 week trial involving 26 married or cohabiting couples conducted by Floyd et al [9], results showed that increasing the frequency of romantic kissing between couples decreases blood cholesterol and perceived stress, and increases the perceived relationship satisfaction. These effects were not observed in the control group. Based on the previous experimental findings of real kissing, we hypothesized that mediated kissing with the Kissenger device reduces perceived stress, and increases relationship satisfaction in long distance romantic relationships.
We used two questionnaire measures to assess the relationship satisfaction and perceived stress of participants. Relationship satisfaction was measured with the 7-item Relationship Assessment Scale [17], which includes questions such as "How well does your
b) Experimental Procedure
partner meet your needs?", and "How many problems are there in your relationship?" Perceived stress was measured with the 10-item Perceived Stress Scale (PSS) [5]. Questions asked participants how often they had dealt with anger, irritations, nervousness, etc. We rephrased the questions by asking participants to reflect on "the past day", instead of "the past month" as stated in the original questionnaire.
a) Participants
Potential participants were invited to complete an online prescreening questionnaire to determine their eligibility for the study. To be considered eligible, participants had to 1) be 18 years and above; 2) be in a romantic relationship for at least 2 months; 3) see their partner for 3 times a month or less; 4) report no history of diagnosis of depression or other mood-related disorders; 5) have access to the Internet and mobile phones.
50 eligible couples in a long distance relationship were recruited to participate in this study. The couples were randomly assigned to experimental group and control group, each group consisted of 25 couples.
A Kissenger device along with a detailed instruction booklet were delivered to each participant in the experimental group before the start of the trial. The
Before the one week trial started, an online questionnaire was sent to participants in both experimental group and control group to assess their pretest relationship satisfaction and perceived stress level. The two-part questionnaire consisted of 17 items measured on a 5-point Likert scale. A higher score on the scale indicates higher relationship satisfaction, or higher perceived stress.
experimenter arranged a video call session with each couple to demonstrate the use of the Kissenger device, and to make sure the couple could correctly operate the Kissenger devices.
During the one week trial, participants were given instructions to communicate with their partner everyday using all of these three methods: 10 minutes video call, 10 minutes phone call, and 10 text messages. Couples in the experimental group were instructed to use the Kissenger during their communication everyday, whereas couples in the control group communicated without using Kissenger.
At the end of the trial, a short interview was conducted with each couple in the experimental group to gather feedback on their experience of using Kissenger and how it had affected their feelings and relationships with their partner. Interview questions included: "How has using Kissenger changed your relationship with your partner?", "Do you think Kissenger has improved your physical intimacy with your partner?", etc.
c) Results and Discussions
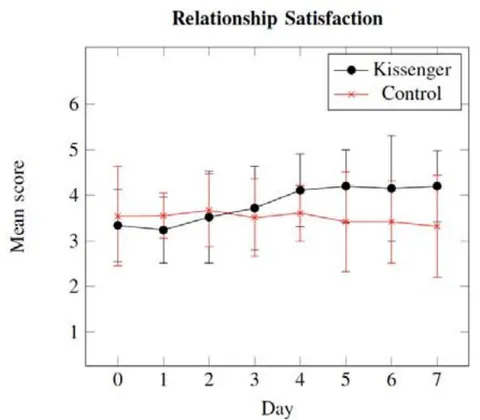
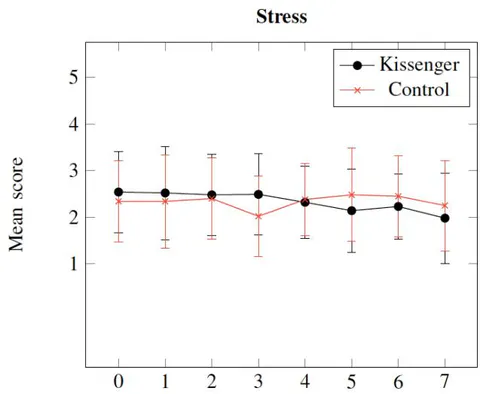
Tests on the outcome variables, relationship satisfaction and perceived stress, were conducted using ANCOVA with one-tailed pairwise mean comparisons by condition. Figure 11 reports the daily means and standard deviations for both outcome variables during the one week trial. Day 0 values represent the pretest results obtained from participants before the trial. ANOVA tests confirmed the assumption that Day 0 relationship satisfaction and stress values were not significantly different between the experimental and control groups.
Visual analysis of results for relationship satisfaction revealed that the experimental group experienced a steady increase from Day 1 to Day 4, and remained roughly constant until the end of the trial. The control group did not show any significant increase or decrease throughout the week. We examined the effects of the Kissenger device on relationship satisfaction using ANCOVA with condition (experimental vs. control) as the fixed factor, Day 0 relationship satisfaction as the covariate, and Day 7 relationship satisfaction as the dependent measure. ANCOVA revealed a significant effect for condition (F = 5:24, p < 0:05, partial ). Consistent with the visual analysis, the experimental group experienced a significant increase in relationship satisfaction (t = -3:28, p < 0:05), whereas the control group did not show a significant difference during the trial.
Similarly, we analysed the effects of Kissenger on perceived stress using ANCOVA with condition as the fixed factor, Day 0 stress as the covariate, and Day 7 stress as the dependent measure. ANCOVA revealed a significant effect for condition (F = 3:21, p < 0:05, partial ) on perceived stress. Paired samples t-test also confirmed that the experimental group experienced a significant decrease in stress levels (t = 3:12, p < 0:05). The control group did not differ significantly in this experiment.
The results confirmed our hypothesis that couples in a long relationship experience increased relationship satisfaction and reduced stress when they engage in mediated kissing using the Kissenger device.
This shows that remote mediated kissing has similar benefits on people's psychological well-being as
VII. CONCLUSION
In this paper, we identified a gap between research and industrial applications in haptic technologies for digital com- munication, and provided a design guideline for integrating interactive force-feedback haptic interfaces in communication devices such as mobile phones. Following such design considerations, a novel haptic kissing device that senses lip pressure and uses dynamic normal force stimulation to transmit realistic sensations of kissing was implemented for mobile phones.
We conducted three experiments with the Kissenger machine and obtained positive results. In the first experiment, we compared participants' ratings of pleasure, arousal, and user experience for mediated kissing with those for real kissing in a lab setting. Results showed that mediated kissing using Kissenger elicited similar ratings for pleasure, arousal and user experience as real kissing. We conducted a unique embodied Imitation Game to investigate the effects of haptic communication in a Turing test. Participants acted as interrogators in the Imitation Game and they had higher odds of winning the game when Kissenger was used during the game with both human and chatbot interlocutors. Lastly, we conducted a one-week trial with real life long distance couples to study the effects of using Kissenger on psychological measures. Couples who used Kissenger for a week experienced a significant increase in relationship satisfaction and decrease in perceived stress levels.